UAV Design Optimization
2024 – presentPreliminary design optimization for a tiltrotor drone under 25 kg and slower than 45 m/s - sizing, aerodynamics, and propulsion in one loop.
On my CV
A few things I've built - research work and weekend projects alike.
Preliminary design optimization for a tiltrotor drone under 25 kg and slower than 45 m/s - sizing, aerodynamics, and propulsion in one loop.
Reinforcement learning for a double pendulum on a cart. One goal-conditioned TQC policy swings both poles up, folds either one over the other, and moves between every up/down pose. It runs live in the browser on this site.
Extended Kalman Filter implementation of 3D simultaneous localization and mapping, written to be readable rather than clever.
Real-time orientation and position on an ESP32-S3. VQF handles attitude, a 9-state EKF fuses the accelerometer with GPS for position, and the board streams it all to a browser over its own Wi-Fi.
Wrist-camera firmware for an ESP32-S3. It streams MJPEG video, detects AprilTags with their pose and distance, runs OV5640 autofocus, and tracks orientation from an optional IMU, all from a dashboard on the camera's own hotspot.
Aerodynamic design, mass and CG budget, and 3D-printable rib export for a sub-250 g, ESP32-S3-controlled trainer, built on AeroSandbox and NeuralFoil.
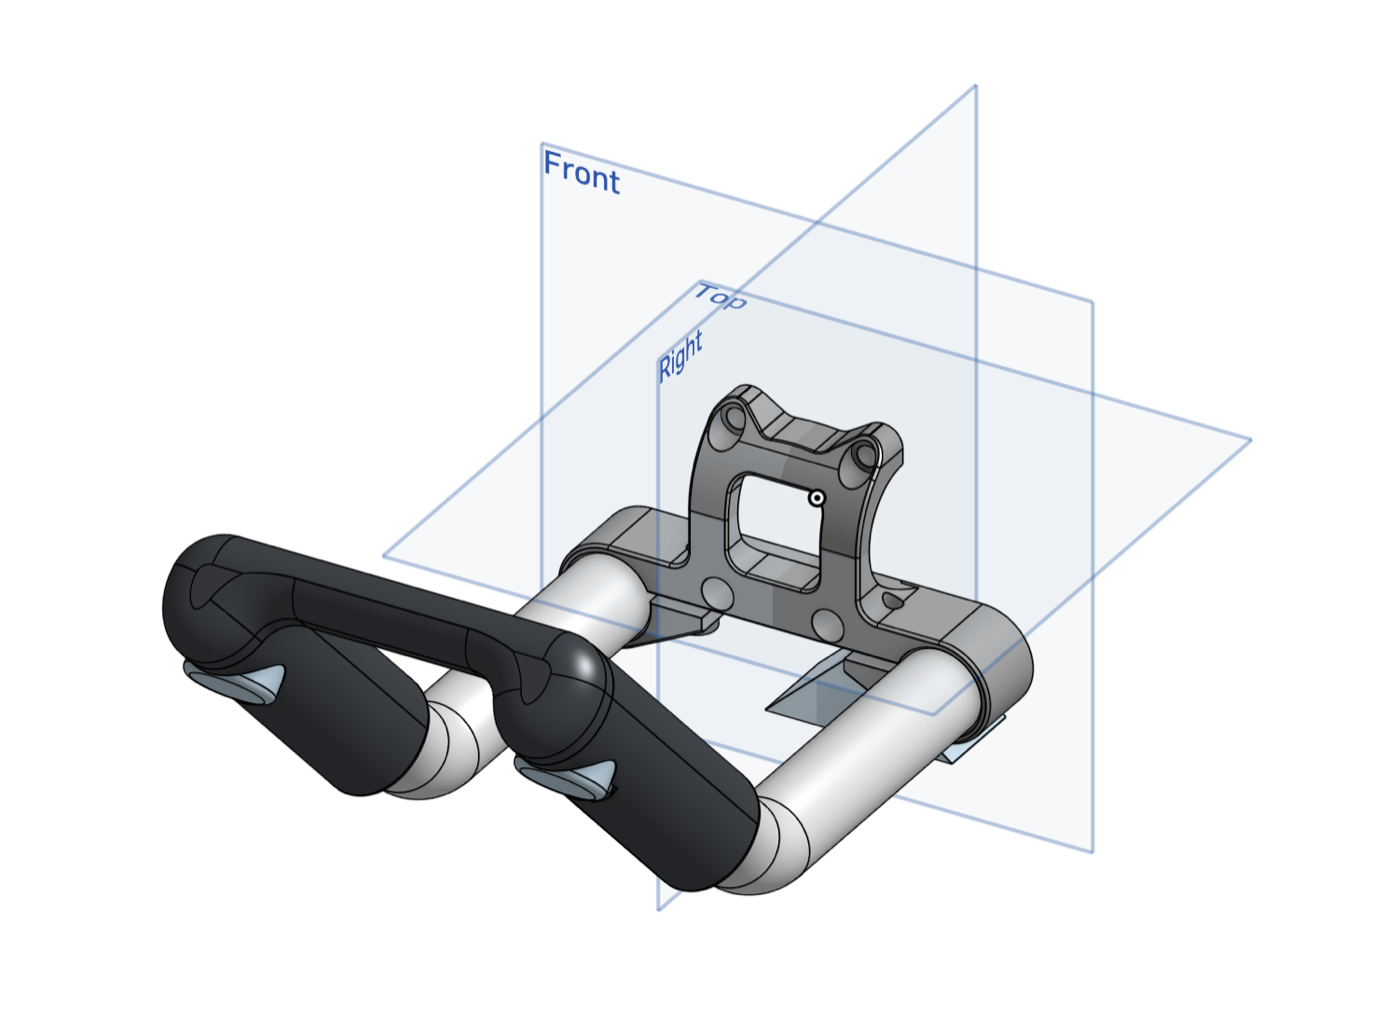
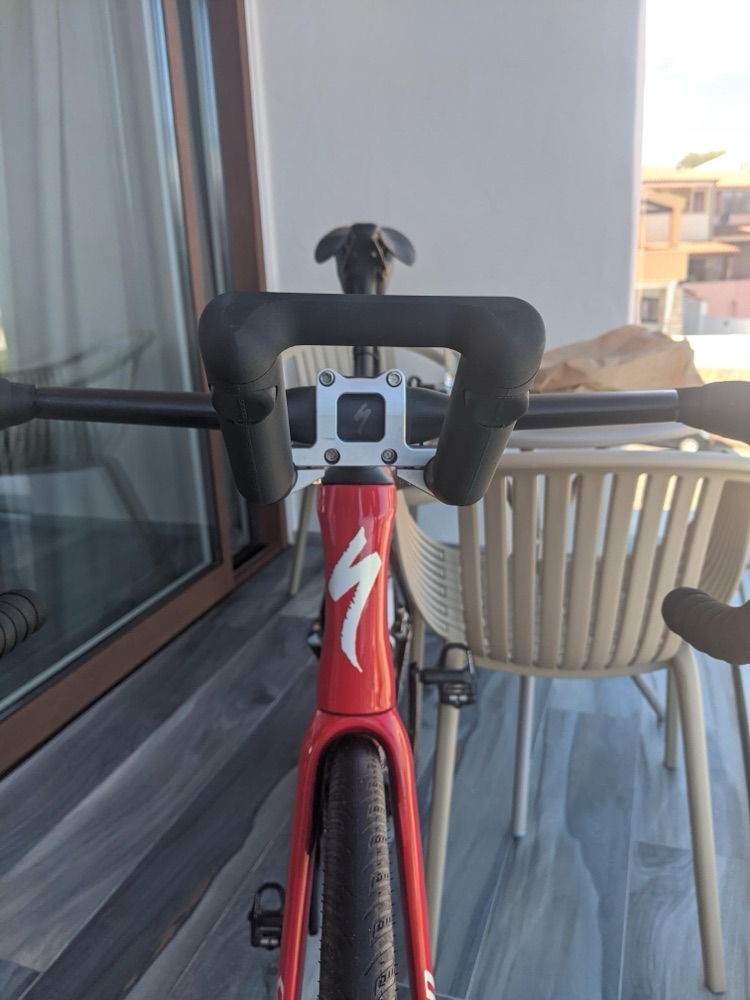
In 2020 I designed, built, and raced on custom hardware for my bike. Modern aerodynamic road handlebars aren't round, so they can't accept standard clamp-on aerobars, and I needed something purpose-built. Aerobars give a big advantage in the moments that decide a race, so I knew the effort would be worthwhile. The design was inspired by an earlier product from Oval Concepts. It worked well for racing, but fatigue testing showed the bolts would fail too early for it to ever become a product.